Megan Minju LeeHi! I'm a Master's student in Robotic Systems Development (MRSD) at Carnegie Mellon University, where I focus on the intersection of planning, control, and learning. My professional background includes a Software Engineering internship at Rivian and time as a Software Test Engineer at Boston Dynamics. Currently, I'm exploring how Reinforcement Learning and Vision-Language Models (VLAs) can push the boundaries of robot manipulation and navigation. My goal is to build intelligent, scalable systems that allow robots to navigate and interact with the messiness of the real world. |
|
Projects
|
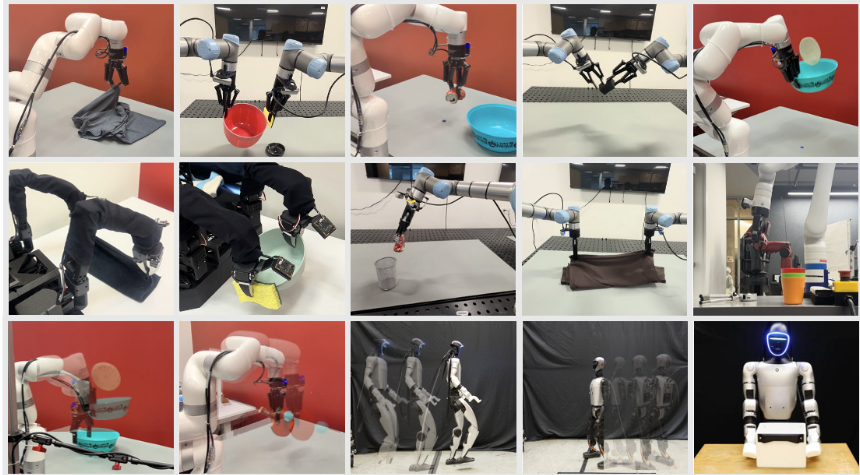
RIO: Flexible Real-time Robot I/O for Cross-Embodiment Robot LearningPreprint, Under Review |
|
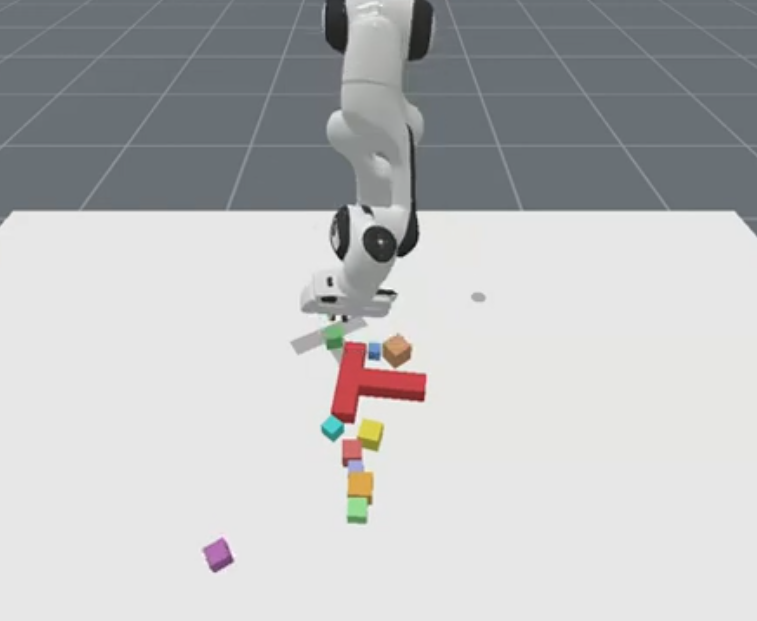
POLARIS: Hybridized classical planning and reinforcement learning frameworkHybridized classical planning and reinforcement learning framework for long-horizon robot manipulation. An LLM decomposes tasks into subgoals via PDDL predicates, then a policy assignment module dynamically selects between classical motion planning (RRT*) and learned RL policies (PPO) per subgoal, combining the reliability of classical methods with the adaptability of learned behaviors, with automatic fallback upon failure. |
|
ASPEN: Spectral-Temporal Fusion for Cross-Subject Brain DecodingPreprint, Under Review ASPEN architecture improves cross-subject generalization in brain-computer interfaces by dynamically weighting more consistent spectral features against temporal signals, significantly reducing the need for individual user calibration. |
|
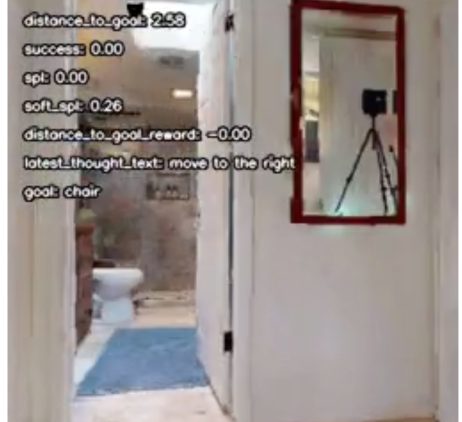
VLM-Guided Subgoal Planning for Indoor Navigation in Habitat-LabImprove robot navigation efficiency and success rates in the Habitat simulator by integrating a "Think" action that allows PPO-based reinforcement learning policies to leverage Vision-Language Models for generating semantic subgoals. |
|
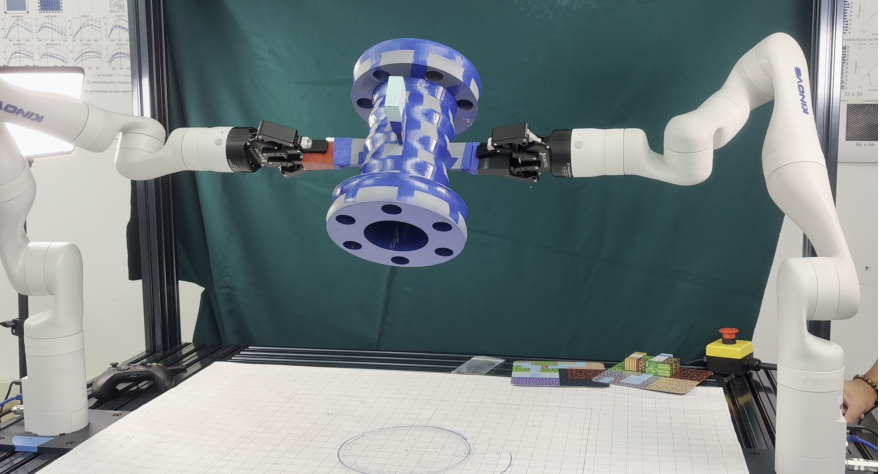
CAPSTONE: Multi Agent Geometric Inspection and ClassificationBimanual manipulation system designed to perform active inspection through coordinated motion and 3D reconstruction. |
|
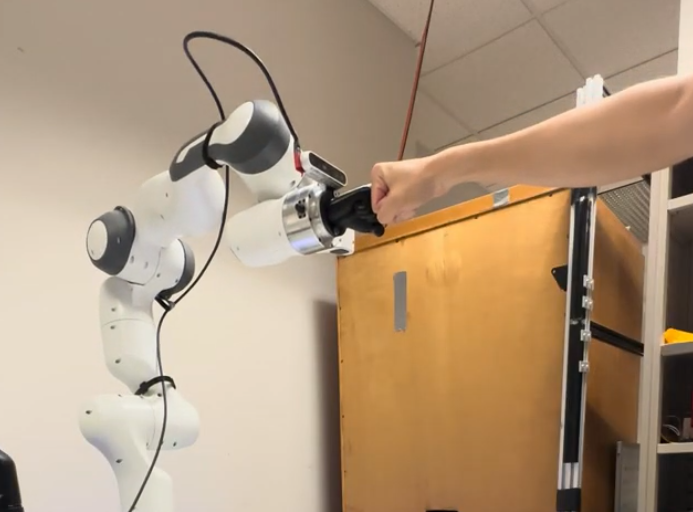
Bumpkin: A Fist-Bumping Robot CompanionRobot arm that can identify when a human wishes to fist bump, track the closest fist, continuously tracks the target motion with the use of dynamic trajectory execution, and proceeds to bump when the fist is within a threshold distance from the tracked fist. |
|
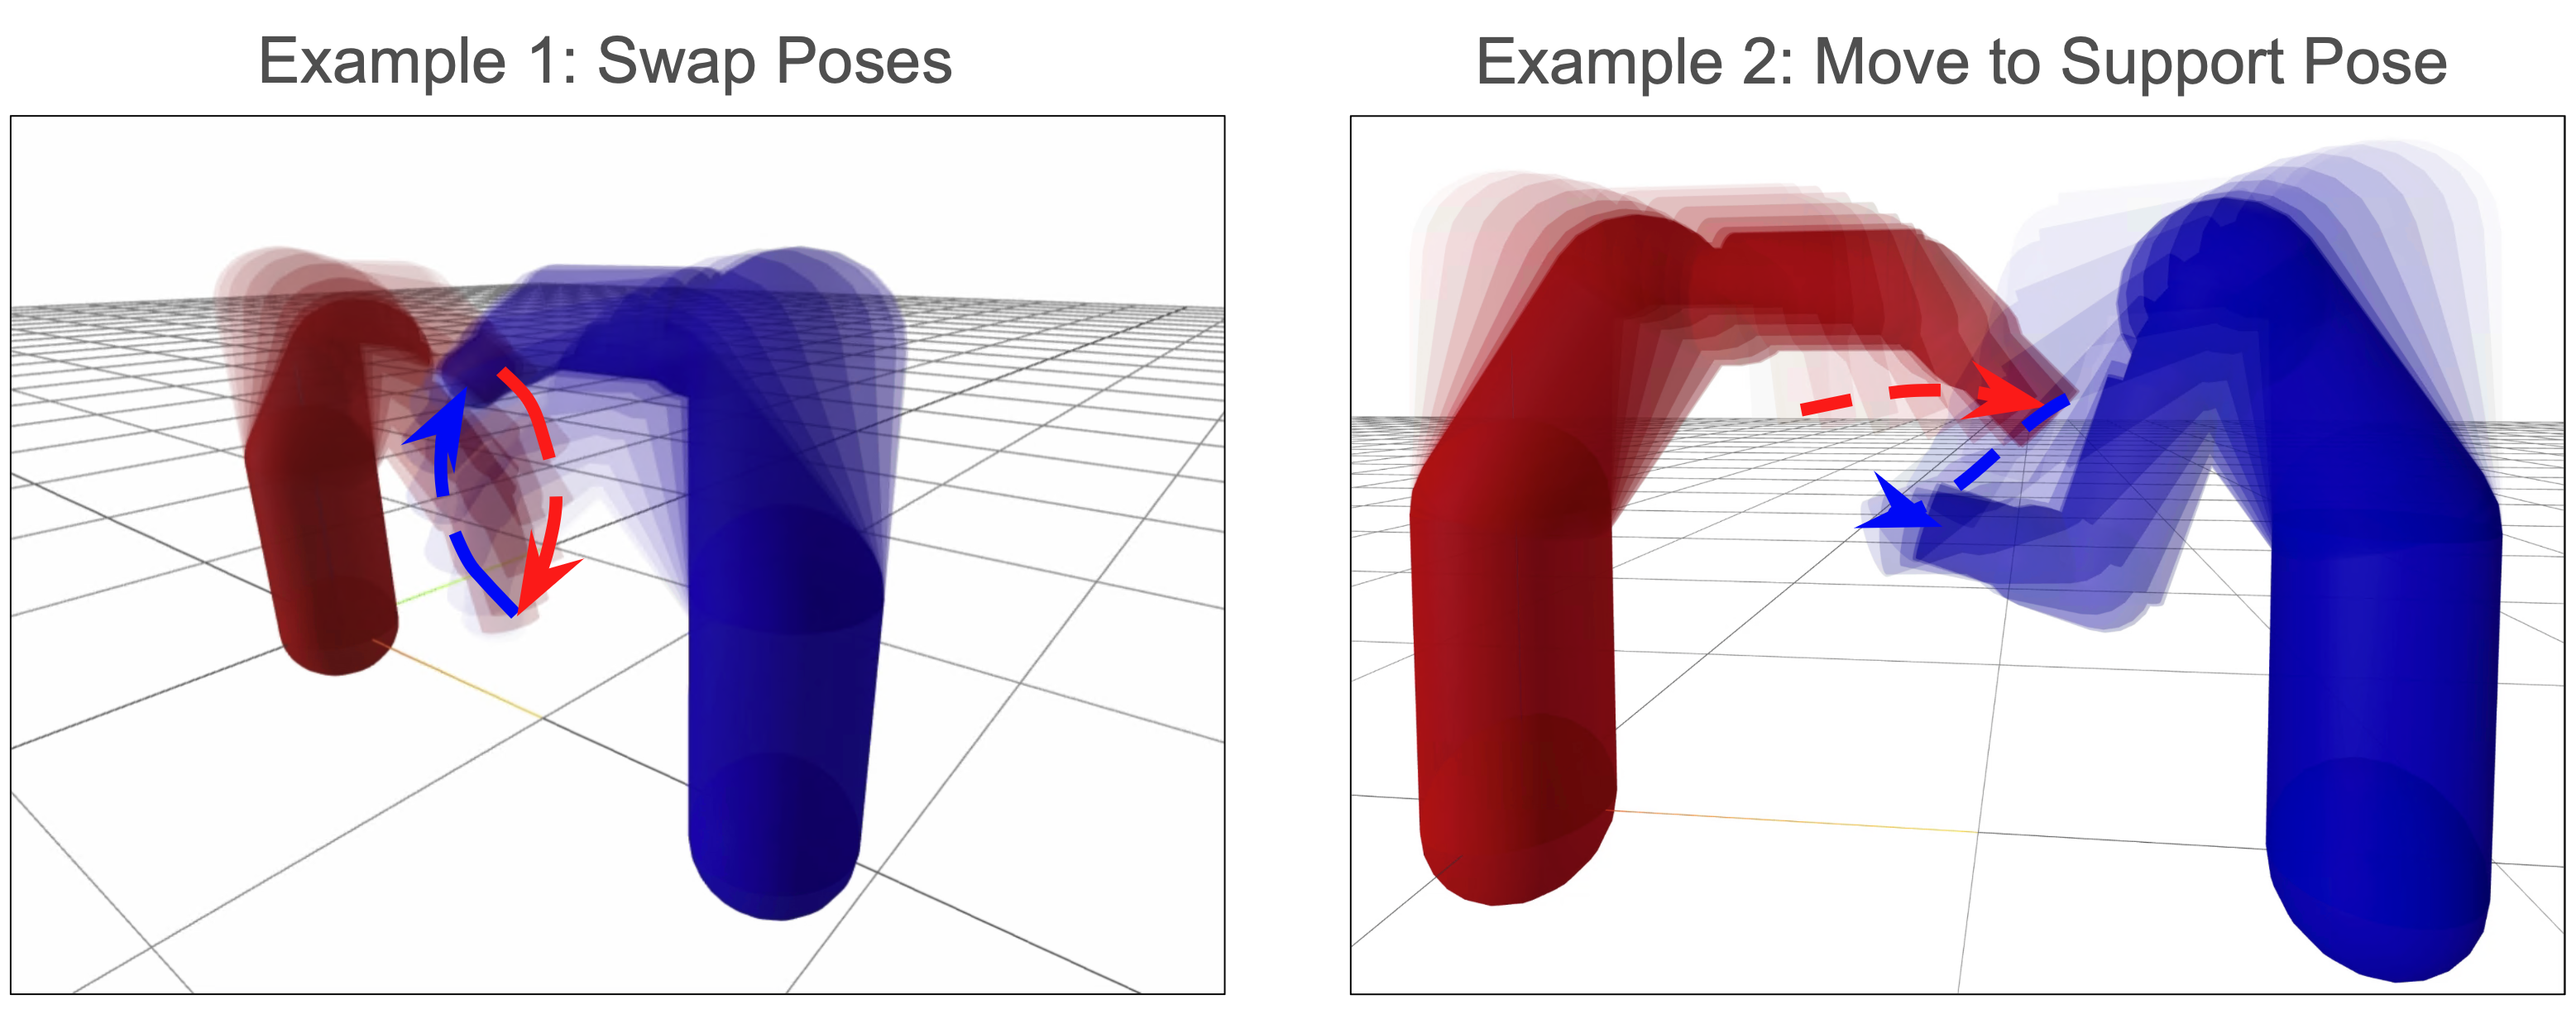
Nonlinear Trajectory Optimization for Multiple Robot ArmsCentralized multi-robot offline planner set up as a trajectory optimization problem. Given a set of kinematic collision-free paths for each robot, the controller tries to optimize a safe, smooth, and dynamically feasible local trajectory that can be directly executed on all robots online using DIRCOL and ALTRO. |